We build intelligence that understands and moves the real world

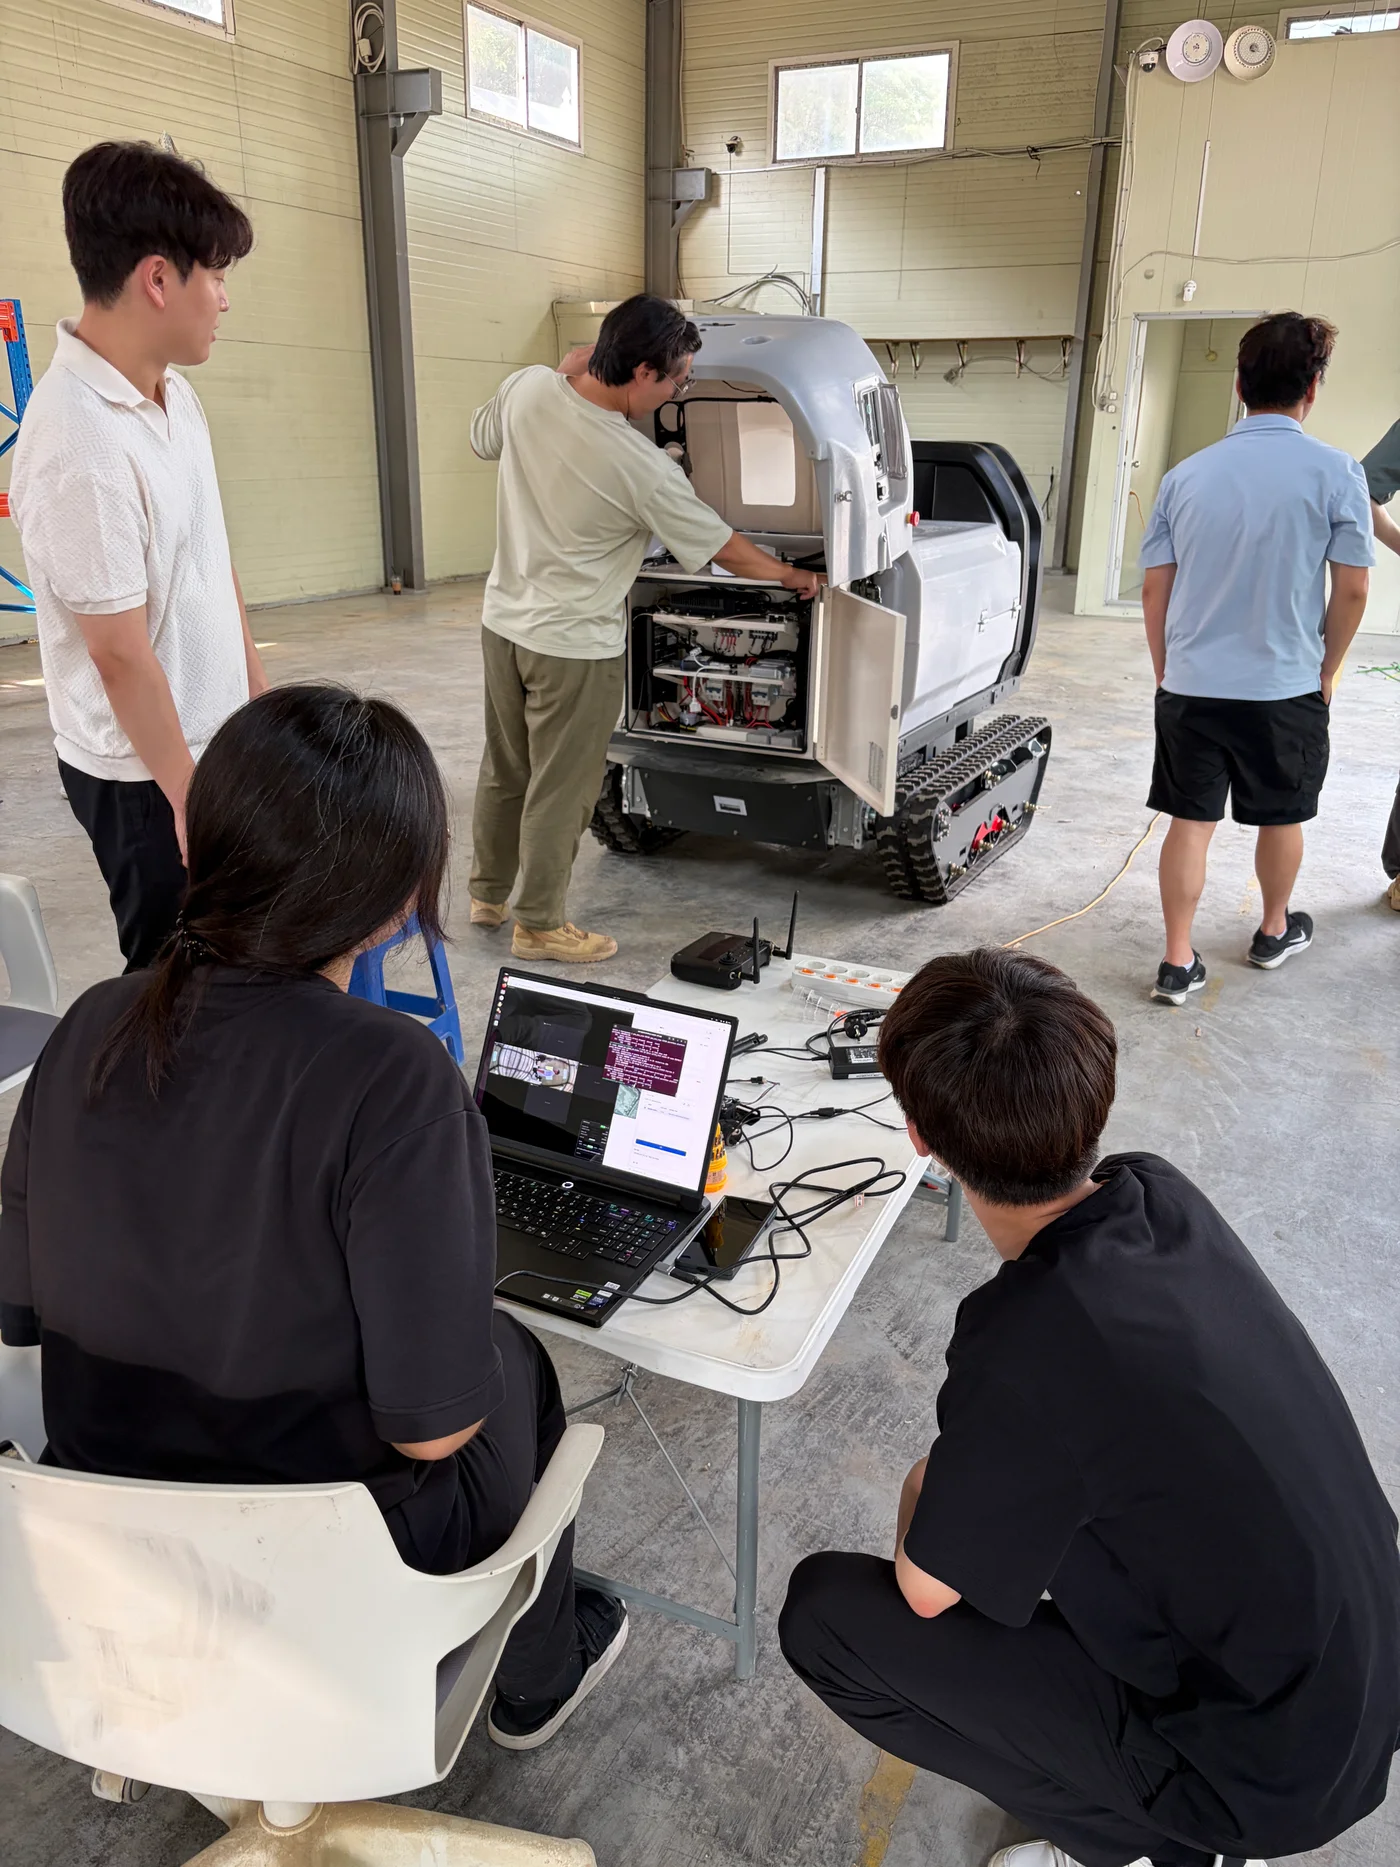
WoRV team members inspecting an autonomous vehicle and working on laptops at a GINT site

AboutWoRV

Established in 2021, the WoRV team is a specialized Physical AI group within maum.ai, with research expertise and field experience in robotics and autonomous driving. With the goal of enabling autonomy in industrial settings, we develop AI for agriculture, logistics, defense, construction, and manufacturing using data collected from hundreds of robots performing real-world tasks.

WoRV Technology

What we do

We train AI on data from real and simulated environments and deploy it to real robots and autonomous vehicles. Data collection, simulation, training, and deployment run as one feedback loop.

Teleoperation & Data Pipeline

Human experience is where robot intelligence begins

Collecting high-quality data for robot learning requires intuitive control across different machines and a consistent data collection process. We integrate teleoperation systems with existing hardware to record skilled operators at work, building pipelines that collect and organize the data into formats suitable for training.

Hardware integration and teleoperation setup

Teleoperation data collection and AI model training

Real2Sim

In virtual environments, we broaden robots’ experience

In the real world, limited robot fleets and space constrain data collection, and dangerous situations are difficult to attempt repeatedly. Using Unreal Engine 5 and NVIDIA Isaac Sim, we recreate the appearance, physical properties, and dynamics of real environments so robots can safely experience and learn from diverse conditions and unexpected situations.

VLA & World Models

We build models that understand context and act autonomously

To handle situations absent from their training data, robots need to understand their surroundings and task context before deciding what to do next. Using visual, language, and action data, we train VLA models for action selection and world models for predicting changes in the physical world, developing models that can act toward a given goal in unfamiliar environments.

Move the divider to compare the two driving scenes.

Sim2Real

We turn skills learned in simulation into real-world movement

Models trained in simulation can perform differently in real environments because of differences in factors such as friction and sensor noise. We apply the models to physical machines, quantify the discrepancies between simulation and reality, and feed the results back into training to improve real-world reliability.

Real World Deployment

In an unpredictable world, we test robots’ decisions and actions

Industrial sites present situations that were not anticipated in the lab, making it important to turn operational problems into improvements. We deploy robots and autonomous vehicles to evaluate their decisions and actions, collecting edge cases and failure data to inform the next round of training and field validation.

Join Us

Build what comes next with us

At WoRV, data collection, simulation, model training, and testing on physical machines are part of one connected process. We see how our research and engineering work in the field, then bring the problems we find back into our research.

If you want to take the technology you build all the way to working robots and vehicles, explore our open positions.

View open positions

Benefits built for deep work.

Top-tier equipment
MacBook Pro and the tools you need
Unlimited robot café
Coffee on tap, no questions asked
Meal allowance
Lunch and dinner covered
Conference travel
Full sponsorship when your paper gets in

Office

제2판교 IT센터

30 Changeop-ro 40beon-gil, Sujeong-gu, Seongnam-si, Gyeonggi-do, Korea (4F)
View map